Robot sensing and navigation data
Uses costmaps, zones, point clouds, odometry, and command streams collected from a Unitree Go2 robotics workflow.
A Unitree Go2 robotics stack for converting factory-floor observations into entropy-based measures of organization, disorder, and run-to-run change.
Accepted · Journal of Intelligent Manufacturing.
This project uses a mobile robotic sensing stack to assess factory-floor organization from spatial, motion, and command-stream data.
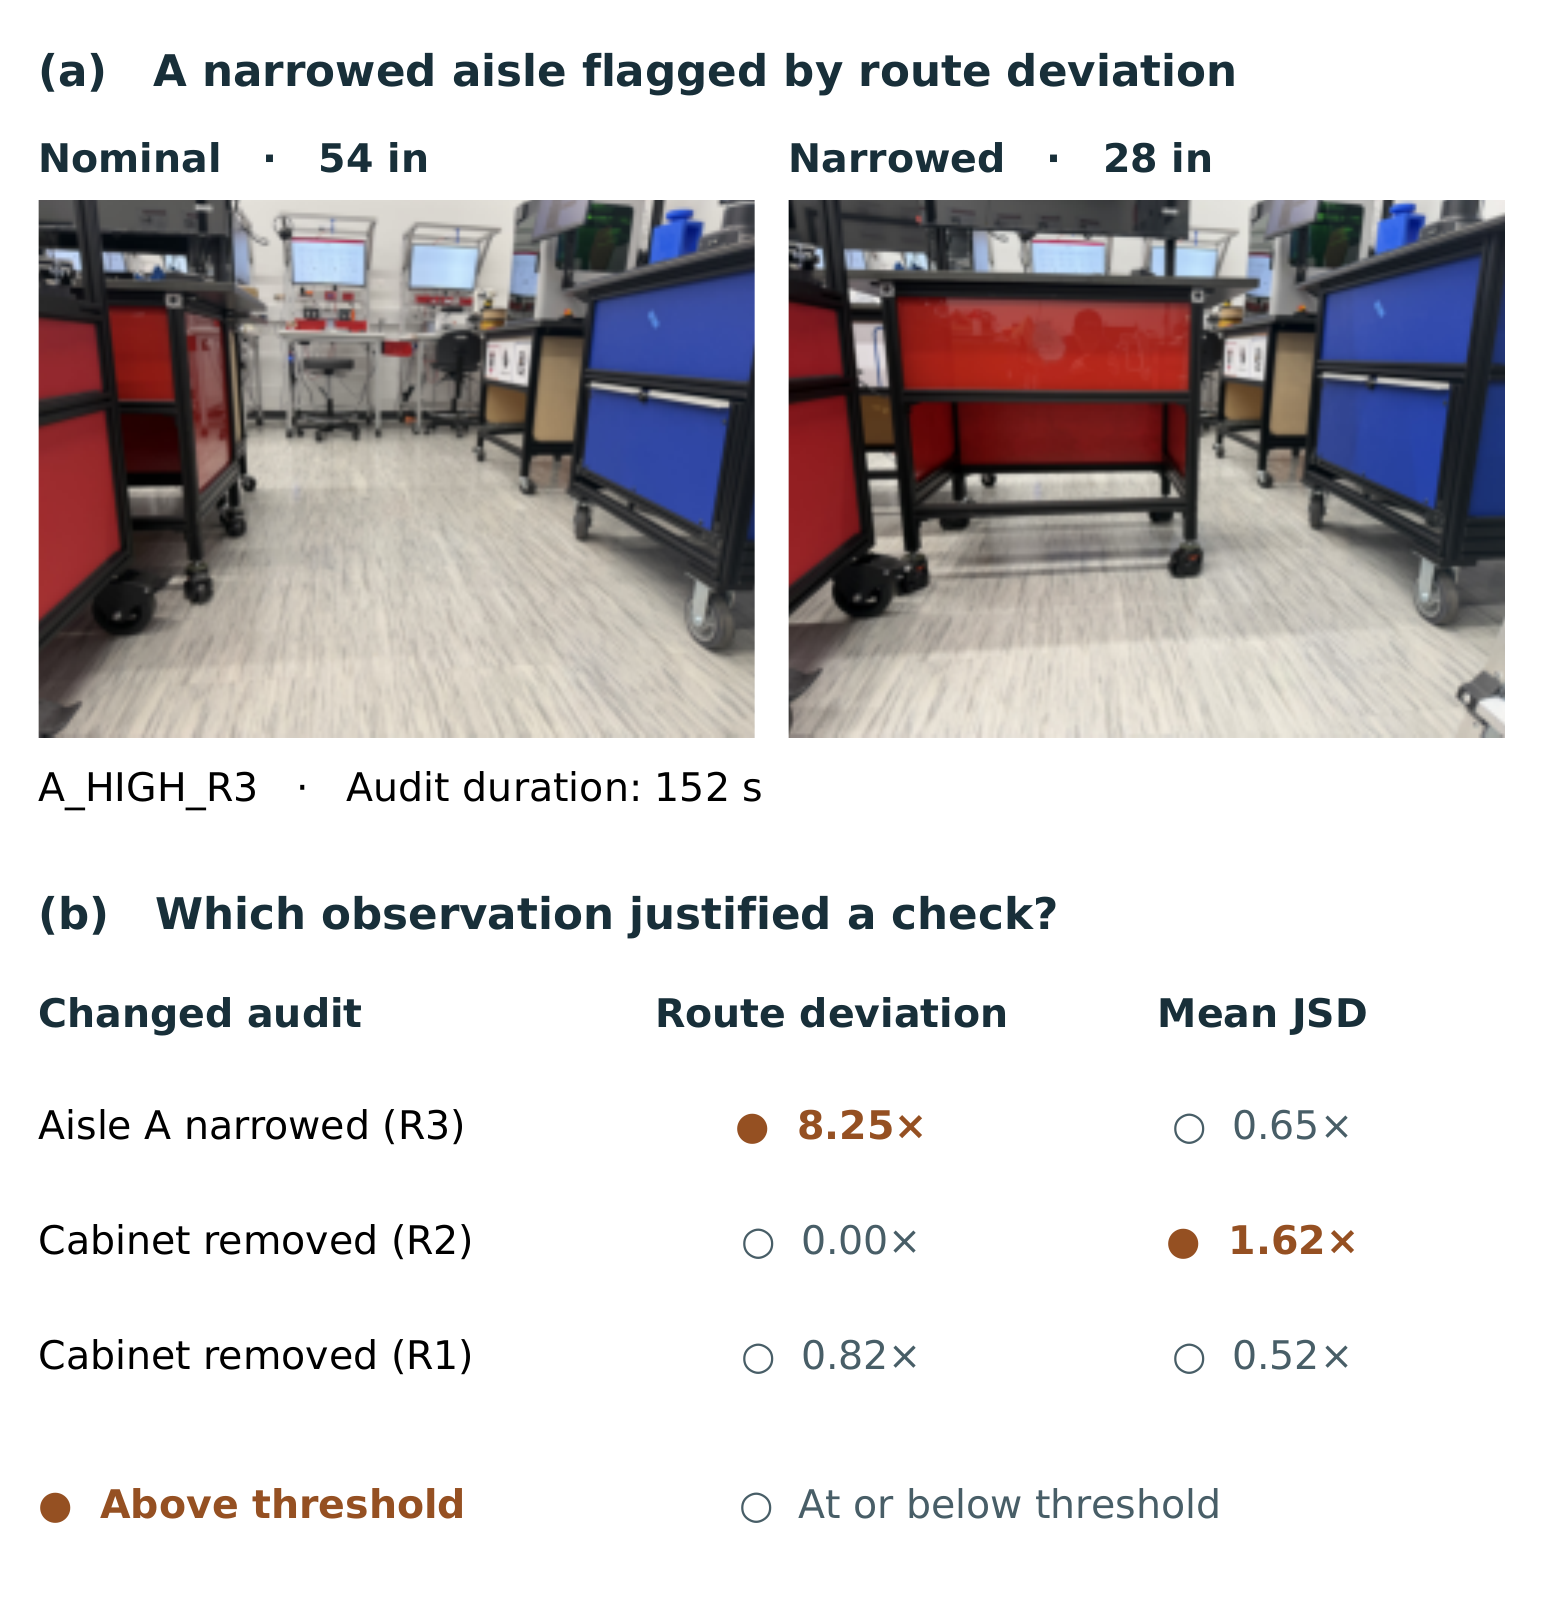
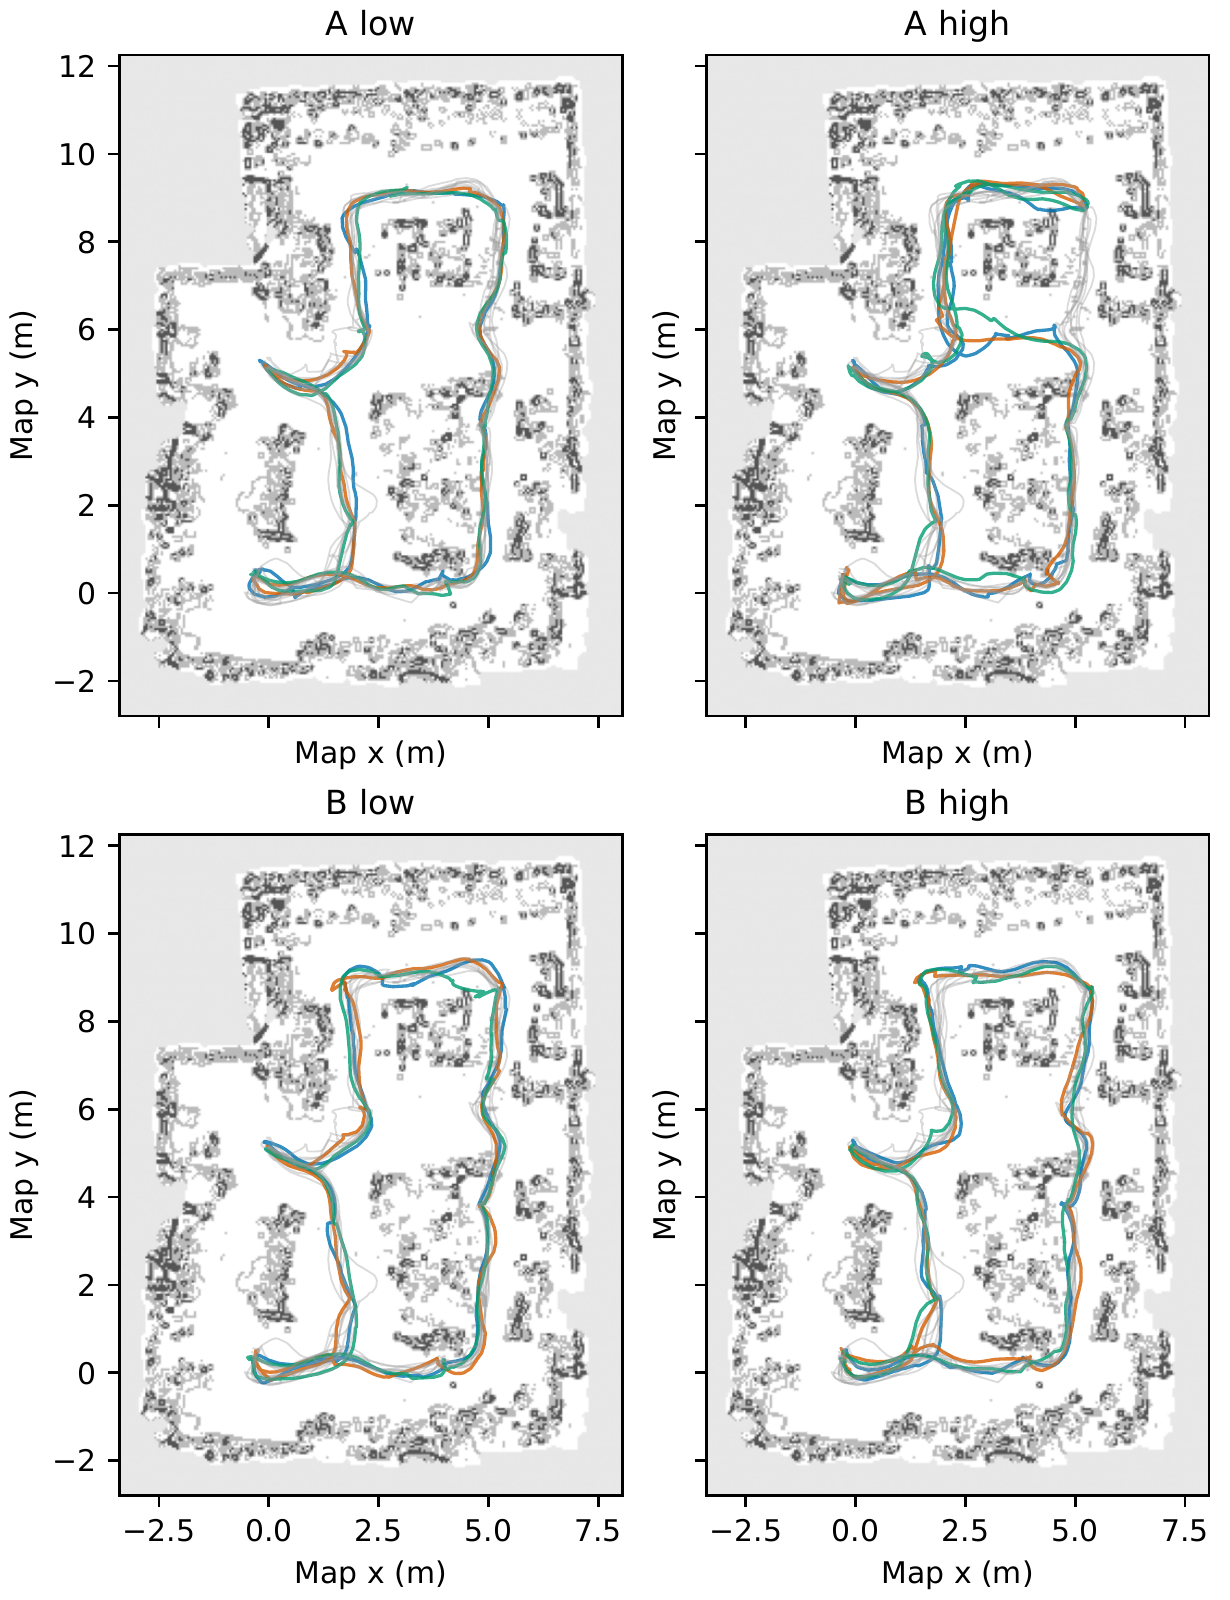
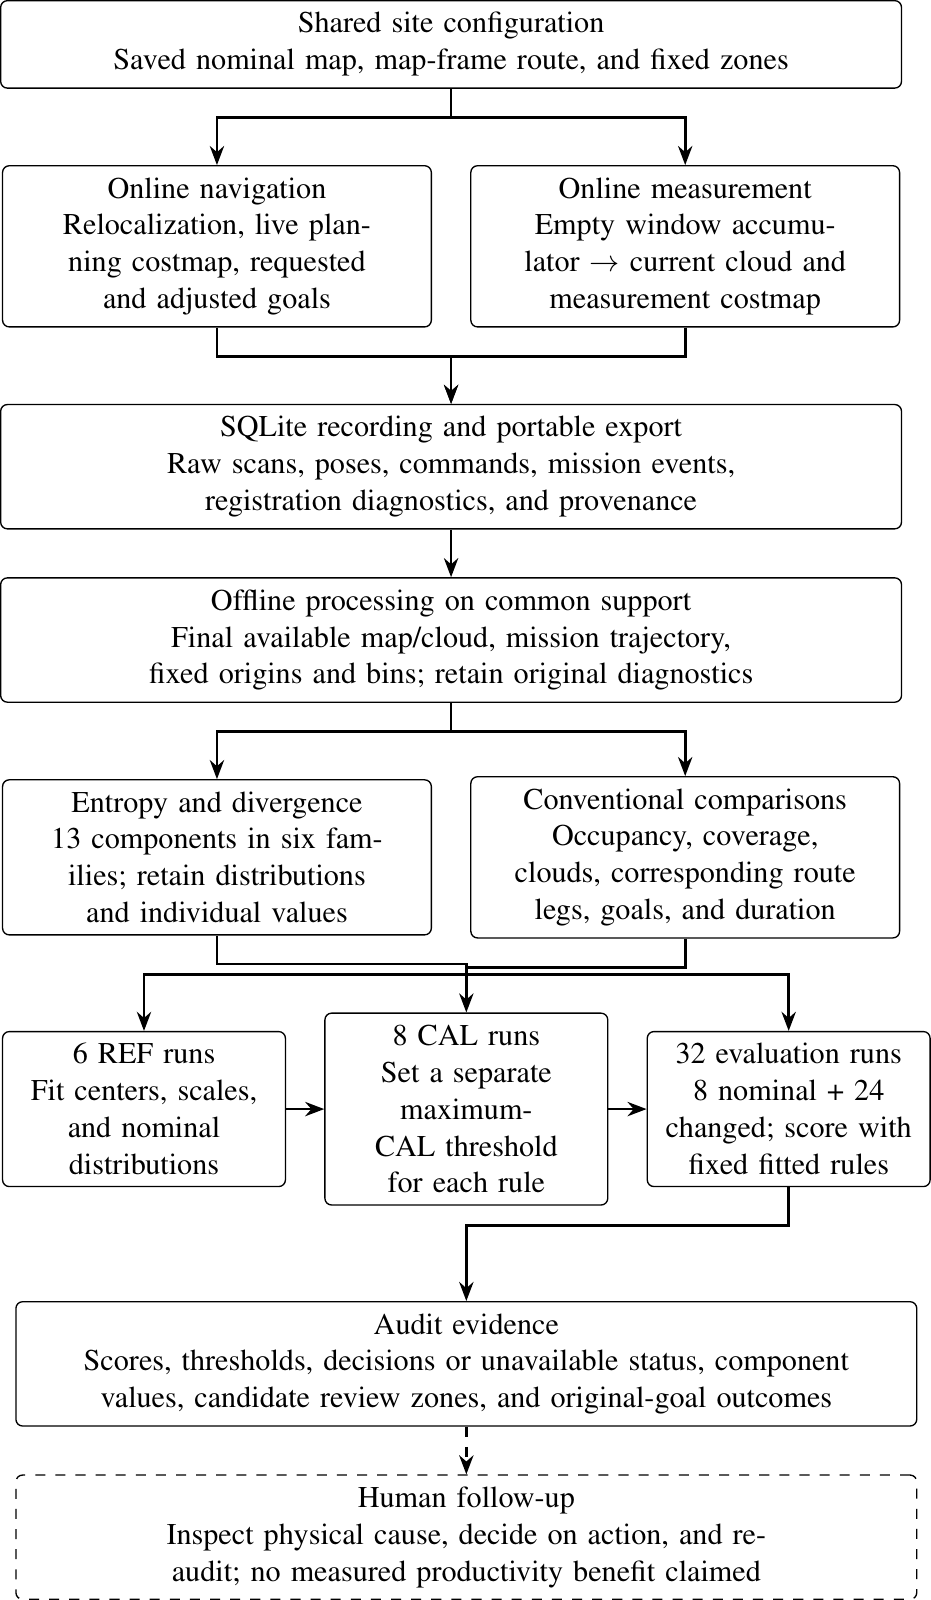
The system converts costmaps, zone definitions, point clouds, odometry, and robot commands into normalized entropy metrics, anomaly scores, and run-level summaries for comparing factory-floor conditions over time.
Uses costmaps, zones, point clouds, odometry, and command streams collected from a Unitree Go2 robotics workflow.
Computes occupancy entropy, zone spatial entropy, point-cloud eigentropy, trajectory entropy, zone visit entropy, and command-stream entropy.
Produces Jensen-Shannon run comparisons, anomaly scores, and normalized AUC over time for comparing floor states and identifying disorder.